NVIDIA Open-Sources OSMO: One YAML Orchestrates Physical AI Training, Simulation, and Robot Testing
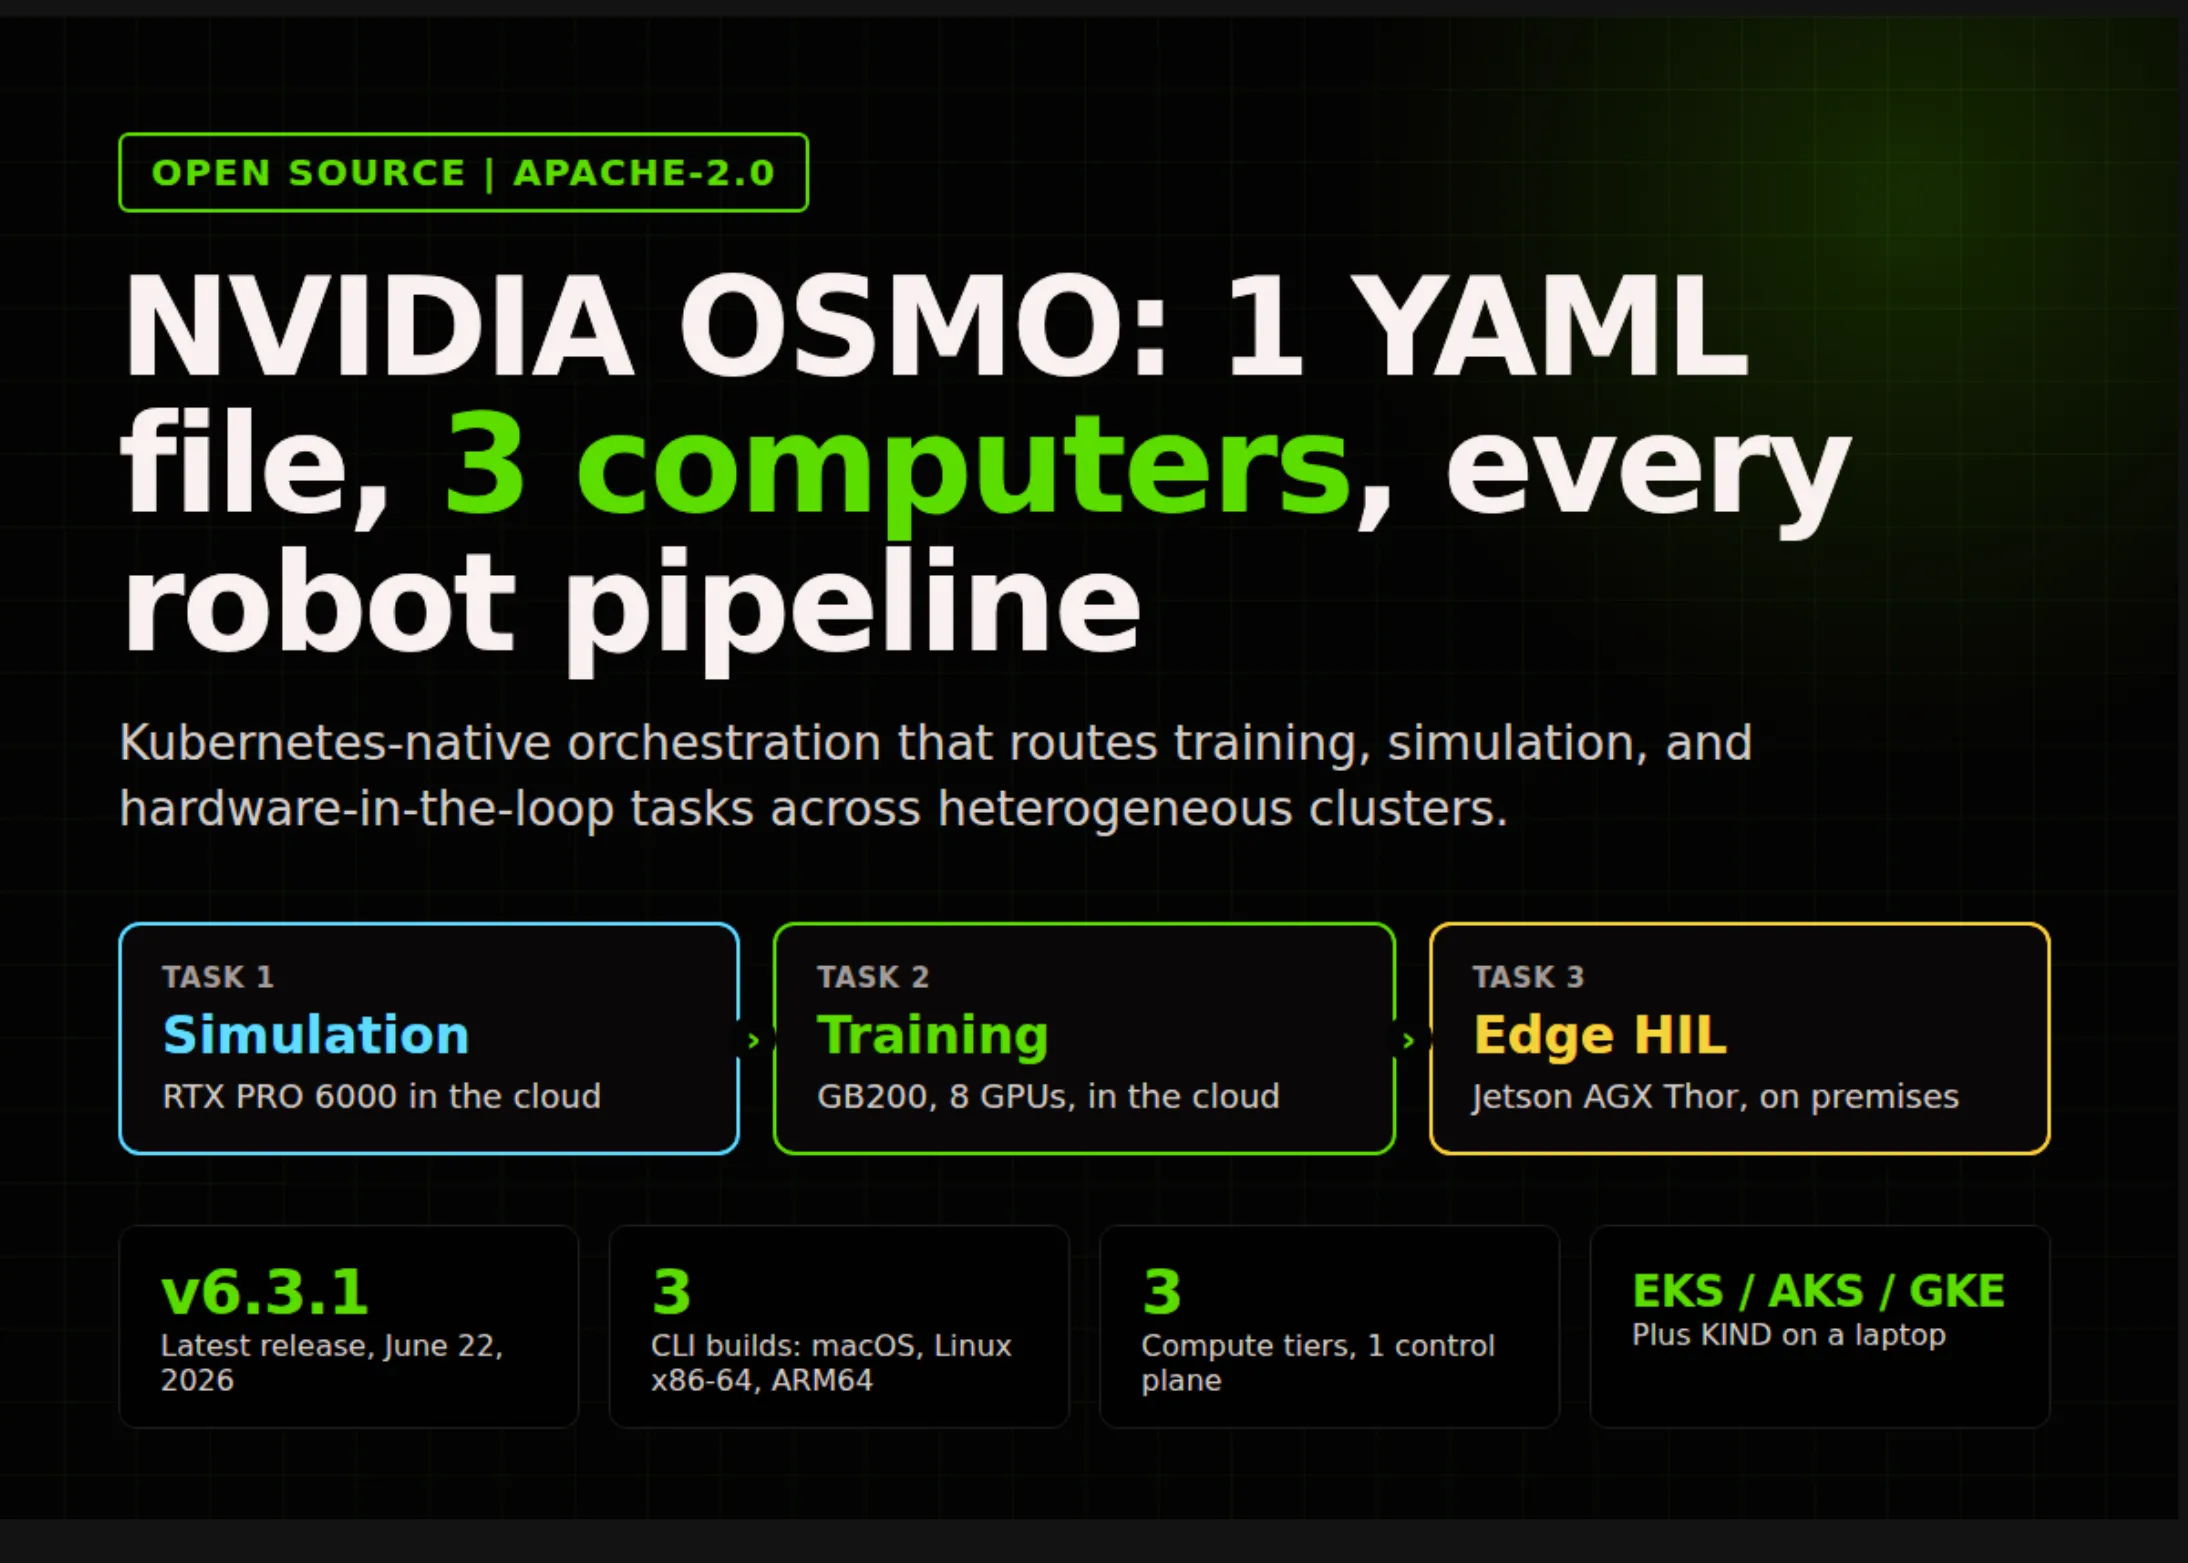
NVIDIA has open-sourced OSMO, the Kubernetes-native workflow orchestrator it uses internally for Project GR00T, Isaac Lab, and Isaac Sim. OSMO lets robotics teams define training, simulation, and hardware-in-the-loop tasks in a single YAML file and routes each one to the right compute tier, from GB200 clusters to Jetson AGX Thor devices, without infrastructure code.
Key Details
- License: Apache-2.0
- Latest release: 6.3.1
- Internal use: Project GR00T, Isaac Lab, and Isaac Sim
- Compute tiers: From GB200 clusters to Jetson AGX Thor devices
What OSMO Does
OSMO is a Kubernetes-native workflow orchestrator. Robotics teams define training, simulation, and hardware-in-the-loop tasks in a single YAML file. Each task is then routed to the right compute tier, without requiring infrastructure code.
